Hojin Lee

profile_nofilter.jpg

Heßstr. 134

80797 München

I am a Postdoctoral Researcher at the Munich Institute of Robotics and Machine Intelligence (MIRMI), Technical University of Munich (TUM), and a visiting researcher in the Scene Representation Group at MIT CSAIL.

My research focuses on robot learning, active perception, and adaptive decision making, with the goal of enabling robots to generalize across tasks, environments, and embodiments.

I received my Ph.D. in Mechanical Engineering from the High Assurance Mobility Control Lab at the Ulsan National Institute of Science and Technology (UNIST), Republic of Korea, advised by Prof. Cheolhyeon Kwon, where I worked on uncertainty-aware planning and control for autonomous systems.

My previous research includes distributed optimal control and estimation for multi-agent systems, agent-to-agent interaction prediction and intent inference, off-road navigation, and continual learning.
Selected publications

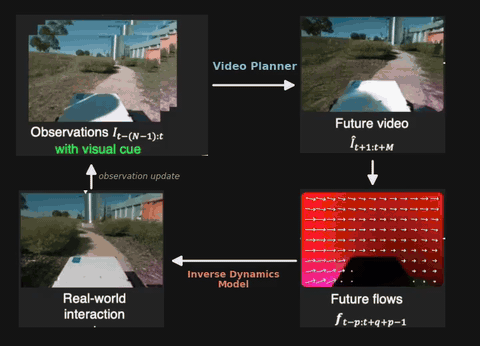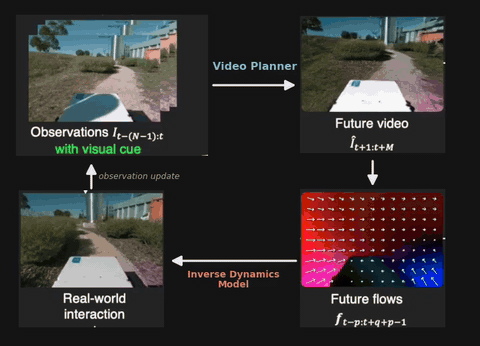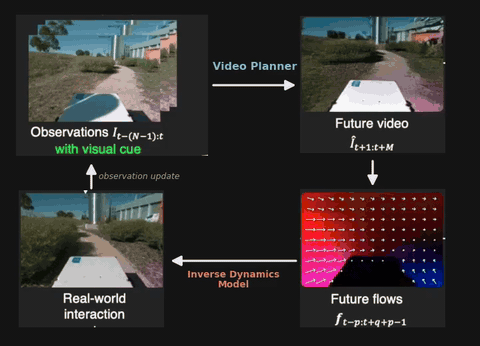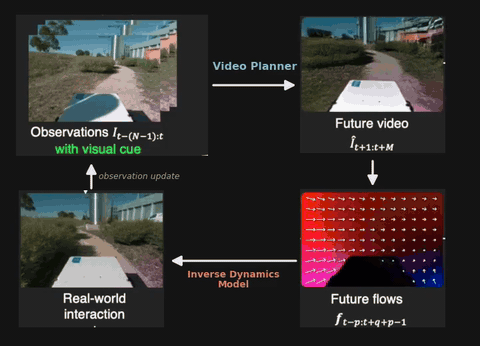
  1. cuenav2026.gif
    Visual Cue Guided Video Planning for Generalizable Robot Navigation
    Hojin Lee, Sizhe Lester Li, Maximilian Hilger, Susie Lu, Achim J. Lilienthal, Vincent Sitzmann, and Daniel A. Duecker
    arXiv preprint arXiv:2609.16737, 2026
  2. taes2026.gif
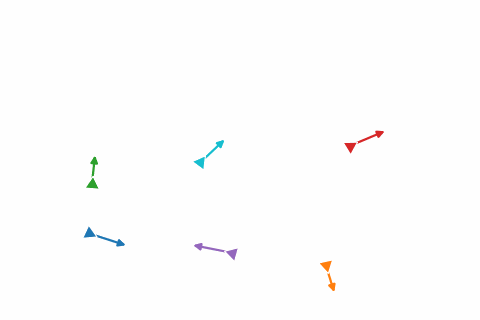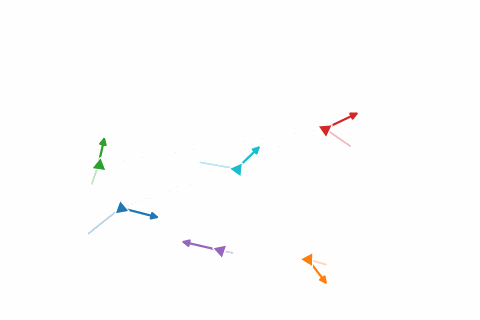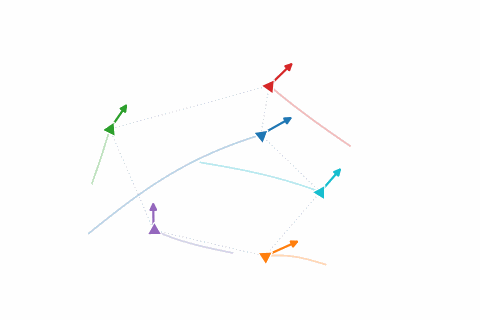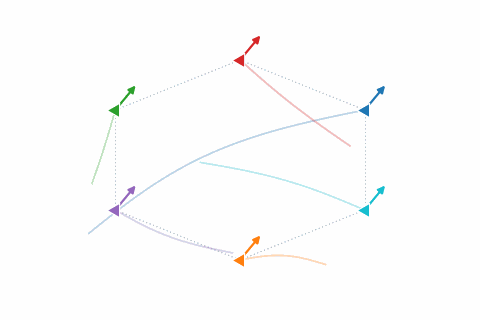
    Formation Control With Orientation Alignment of Distributed Multi-Agent System Using Local Measurements Only
    Chanyong Lee*, Hojin Lee*, Hoai Vu Anh Truong, Donghyuck Lee, Jusang Lee, and Cheolhyeon Kwon
    IEEE Transactions on Aerospace and Electronic Systems, 2026
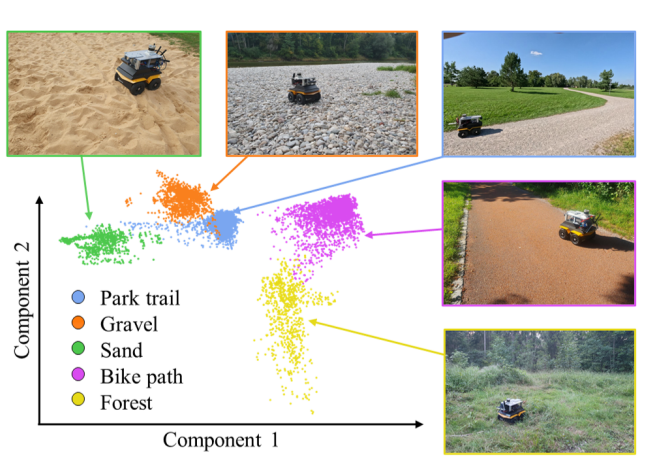
  3. continual_ral_2025.png
    Continual Learning for Traversability Prediction With Uncertainty-Aware Adaptation
    Hojin Lee, Yunho Lee, Daniel A Duecker, and Cheolhyeon Kwon
    IEEE Robotics and Automation Letters, 2025
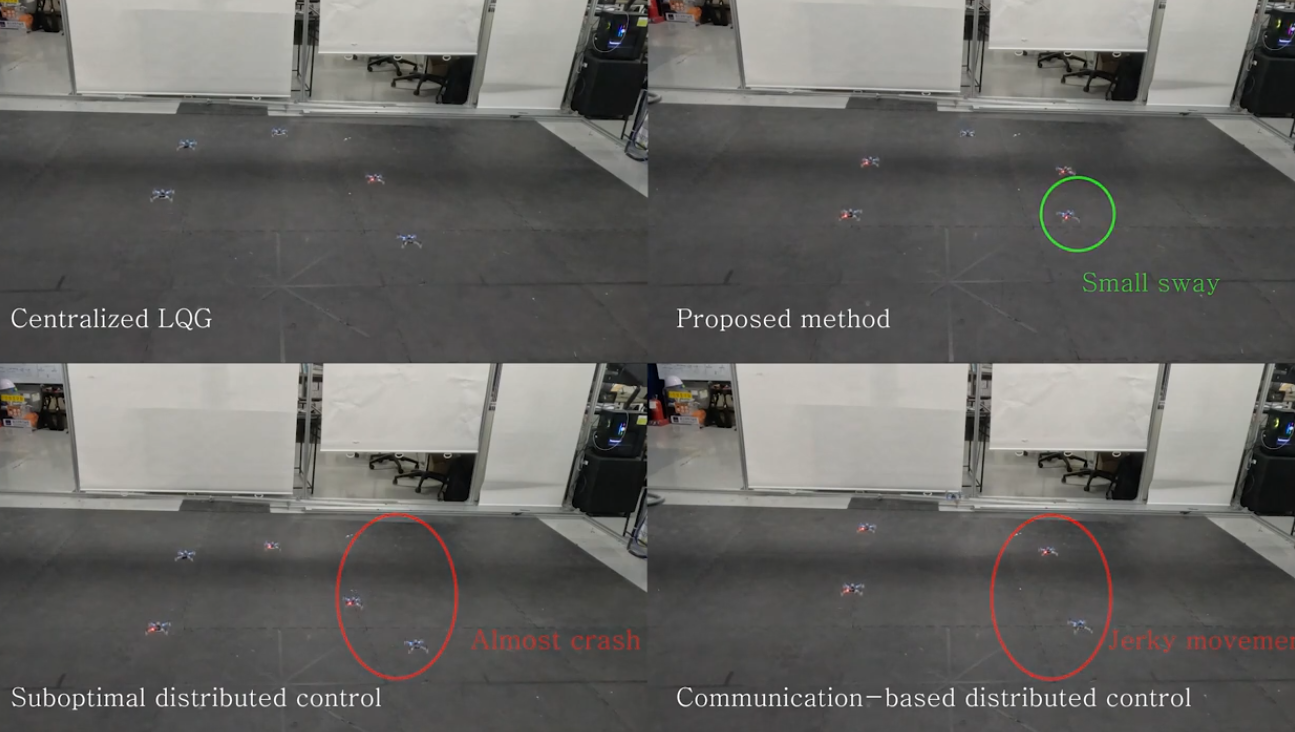
  4. iet2024.png
    Linear quadratic control and estimation synthesis for multi-agent systems with application to formation flight
    Hojin Lee, Chanyong Lee, Jusang Lee, and Cheolhyeon Kwon
    IET Control Theory & Applications, 2024
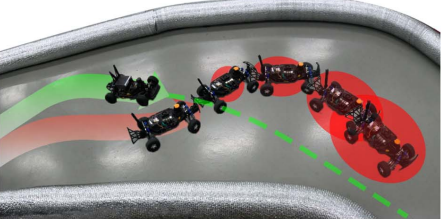
  5. ral2024.png
    Kernel-based Metrics Learning for Uncertain Opponent Vehicle Trajectory Prediction in Autonomous Racing
    Hojin Lee, Youngim Nam, Sanghun Lee, and Cheolhyeon Kwon
    IEEE Robotics and Automation Letters, 2024
  6. icra2023.png
    Learning-based Uncertainty-aware Navigation in 3D Off-Road Terrains
    Hojin Lee, Junsung Kwon, and Cheolhyeon Kwon
    In 2023 IEEE International Conference on Robotics and Automation (ICRA), 2023